|
Young-Chae Son Welcome! I'm Young-Chae Son, a Ph.D. student at Dongguk University’s Interactive Robotics Lab, supervised by Prof. Soochul Lim. I work on Vision-Language Models (VLMs) and Vision-Language-Action (VLA) models for task planning and manipulation on real robotic systems. My research asks how a robot can make reliable decisions when visual observations alone do not reveal enough about the current task state. Rather than simply adding more sensory inputs, I am interested in determining which information is relevant to the task at hand and how it should influence robot behavior. |
|
Research† Equal contribution * Corresponding author |
|
Yoon-Ji Choi, Young-Chae Son, Soo-Chul Lim* under review A See Selectively, Act Adaptively decomposes bimanual robot manipulation into view-selective perception and interaction-aware action routing to improve robust, long-horizon task performance. |
|
Young-Chae Son†, Jung-Woo Lee†, Yoon-Ji Choi, Dae-Kwan Ko, Soo-Chul Lim* under review A lightweight router for a pretrained VLA that dynamically emphasizes task-relevant sensory streams while attenuating irrelevant ones. |
|
|
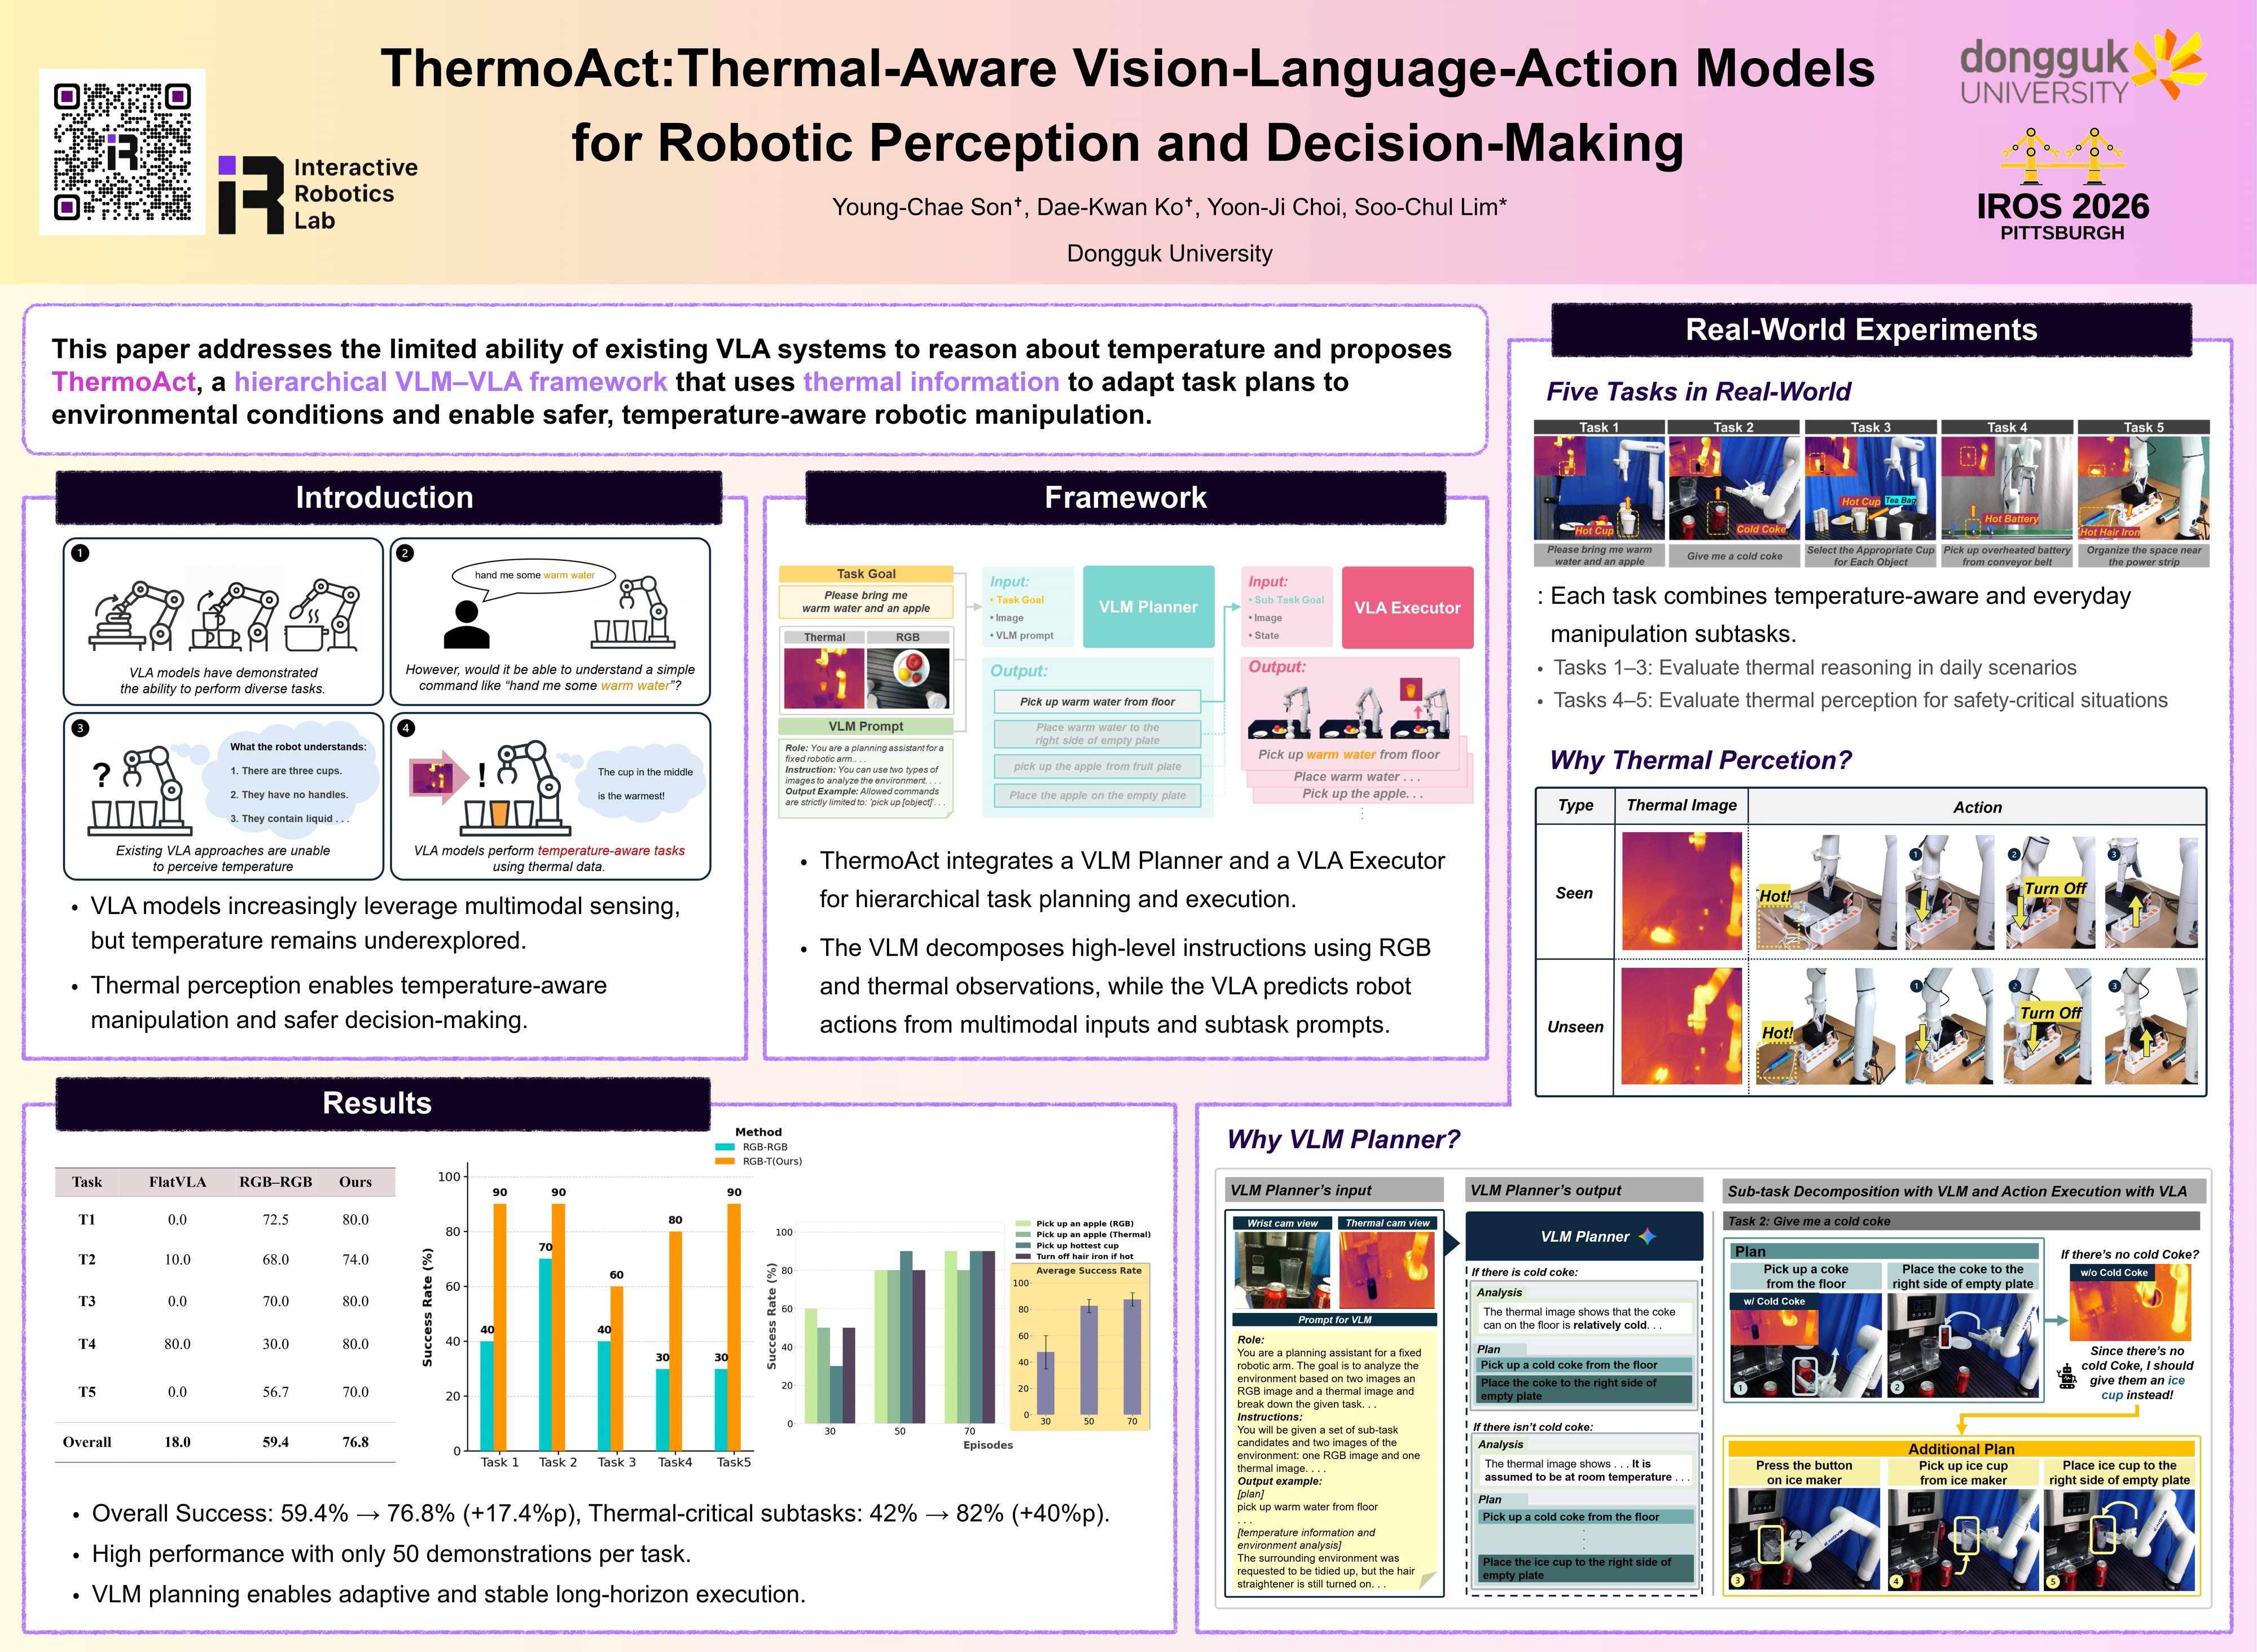
Young-Chae Son†, Dae-Kwan Ko†, Yoon-Ji Choi, Soo-Chul Lim* IEEE Robotics and Automation Letters, 2026 A hierarchical VLM–VLA framework that leverages thermal information to adapt task plans to environmental conditions, enabling safer, temperature-aware robotic manipulation. |
|
|
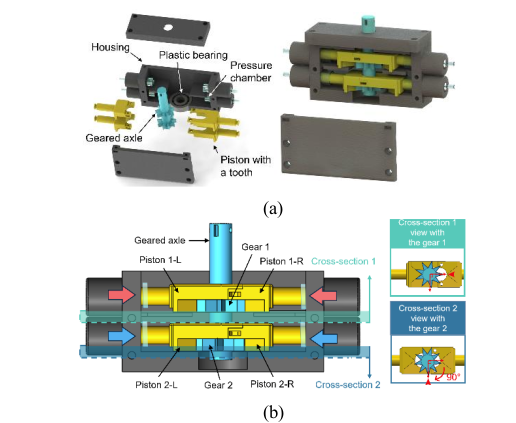
Young-Chae Son†, Sung-Jung Joo†, Po-Gyu Park, Changjin Yun, Soo-Chul Lim*, Hyung-Kew Lee* Conference on Precision Electromagnetic Measurements (CPEM), 2026 Development of a Nonmagnetic Pneumatic Stepper Motor for the Automatic Evaluation of Magnetic Field Uniformity in Helmholtz Coils. |
|
Young-Chae Son, DongHan Lee, Soo-Chul Lim* Intelligent Service Robotics, 2026 Robot task automation framework based on large language models (LLMs) that utilizes both visual and physical information. |
Funded Projects |
|
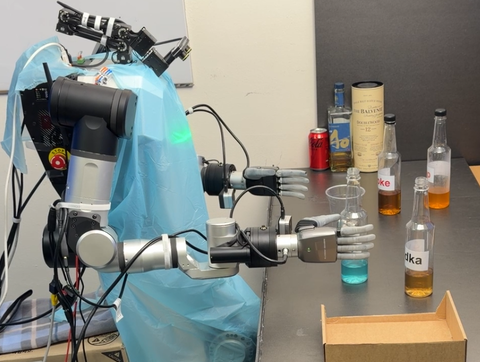
Jul 2025 – Present · Ministry of Science and ICT (MSIT) Keywords: Humanoid Manipulation, Data-Efficient Learning, Robot Foundation Models
|
|
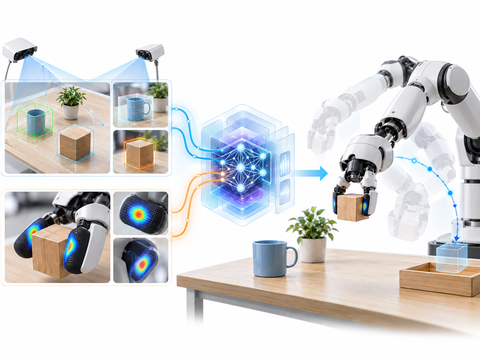
Mar 2025 – Present · National Research Foundation of Korea (NRF) Keywords: Multimodal Robot Learning, Vision/Tactile Perception, Language Models
|
|
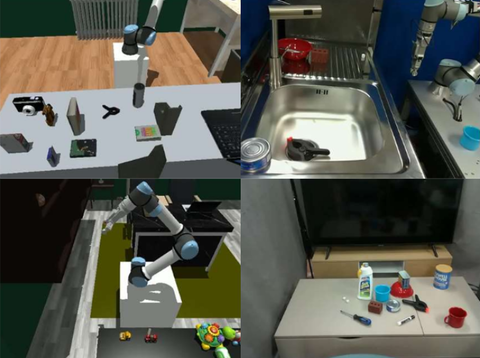
Aug 2024 – Dec 2024 · National Information Society Agency (NIA) Keywords: Robot Data Collection, Manipulation, NVIDIA Isaac Gym
|
Personal Projects |
|
Young-Chae Son, in collaboration with Yoon-Ji Choi, Dae-Kwan Ko, Jung-Woo Lee [Video] Keywords: Long-Horizon Manipulation, VLM Planning, Execution Monitoring
Composing reusable VLA skills for long-horizon manipulation, with a VLM planner that sequences skills and a VLM monitor that checks each step during execution. |
|
|
Young-Chae Son [Video] Keywords: Real2Sim Digital Twin · Robot Teleoperation · VLA Data Augmentation
A digital twin of a real tabletop scene in NVIDIA Isaac Sim, teleoperated through a Meta Quest Pro with eye tracking to collect multi-view VLA training data. |
Experience & Activities |
|
Patent
|
Multimodal Robot System for Task-Context-Based Selective Sensory Utilization
Apr 2026
Korean Patent Application, No. 10-2026-0073734
Method, Apparatus, System, and Computer-Readable Recording Medium for Robot Control Using Thermal Image Information
Apr 2026
Korean Patent Application, No. 10-2026-0067117
|
|
Honors & Awards
|
Global Outstanding Talent Scholarship (Full Tuition Waiver for Ph.D.), Dongguk University
Sep 2025 – Present
Best Paper Award, BK21FOUR AIMS Center Winter Conference, Dongguk University
2026
Grand Prize (1st Place), Transfer Student Mentoring Testimonial, Tech University of Korea
2022
Grand Prize (1st Place), English Presentation Contest, Tech University of Korea
2022
|
|
Presentations
|
The 6th Military Robotics Society Annual Conference, Jeju, Republic of Korea
ThermoAct: Thermal-Aware Vision-Language-Action Models for Robotic Perception and Decision-Making
Oct 2026
IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), Pittsburgh, PA, USA
ThermoAct: Thermal-Aware Vision-Language-Action Models for Robotic Perception and Decision-Making
Feb 2026
Locomotion & Manipulation / Robot Learning Research Groups, Korea Robotics Conference (KRoC), Pyeongchang
Europe Korea Conference on Science and Technology (EKC), Marseille, France
|
|
Teaching
|
Teaching Assistant, Autonomous Robotics
Spring 2026
Teaching Assistant, Autonomous Robotics
Spring 2025
Teaching Assistant, Computational Mechanics
Fall 2024
Teaching Assistant, Autonomous Robotics
Spring 2024
Teaching Assistant, Fluid Mechanics
Fall 2023
|
|
|